

Novel 1 - X-Wing Quadflapper
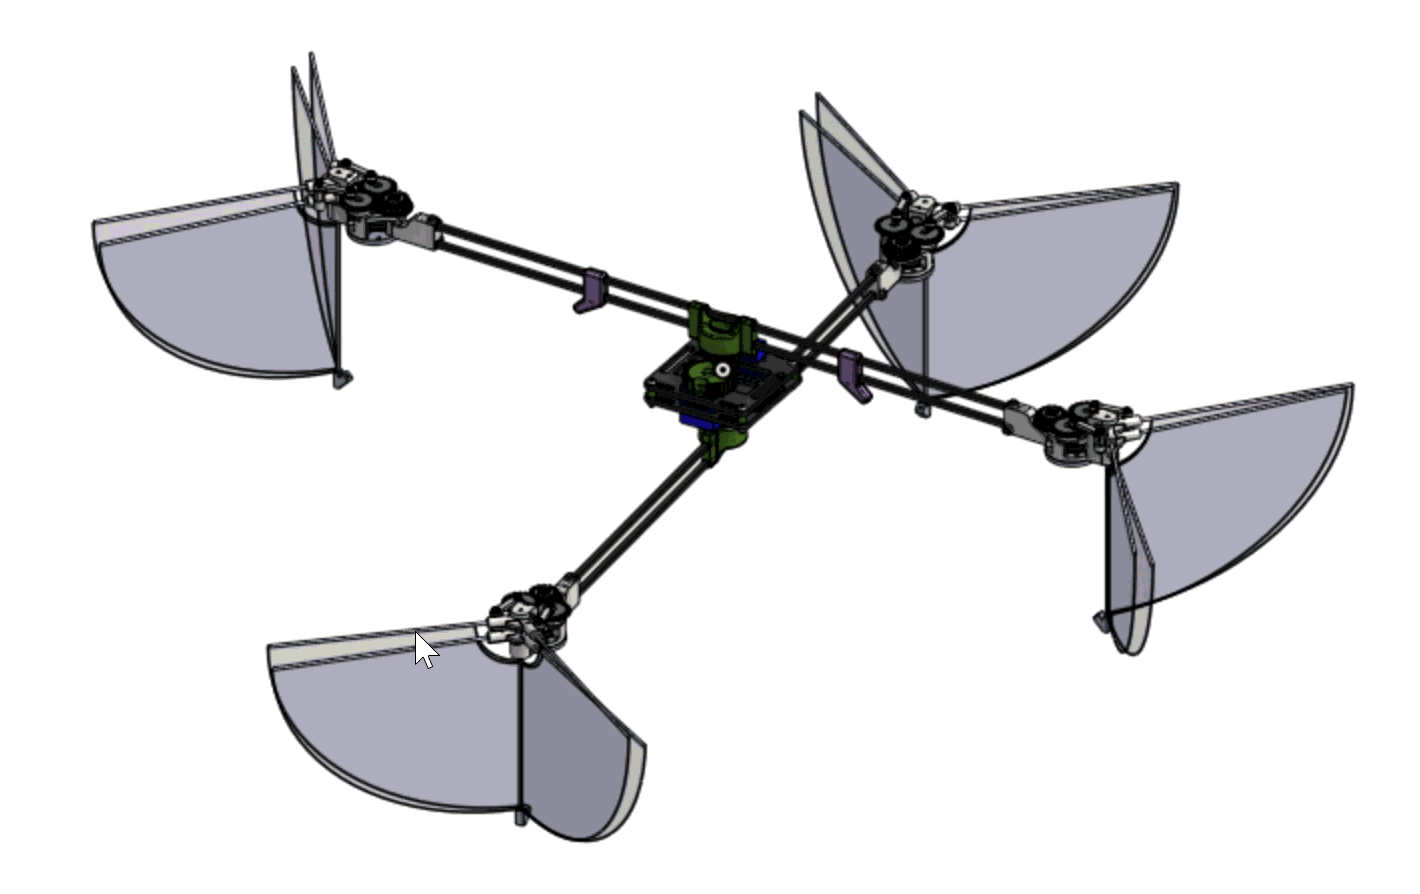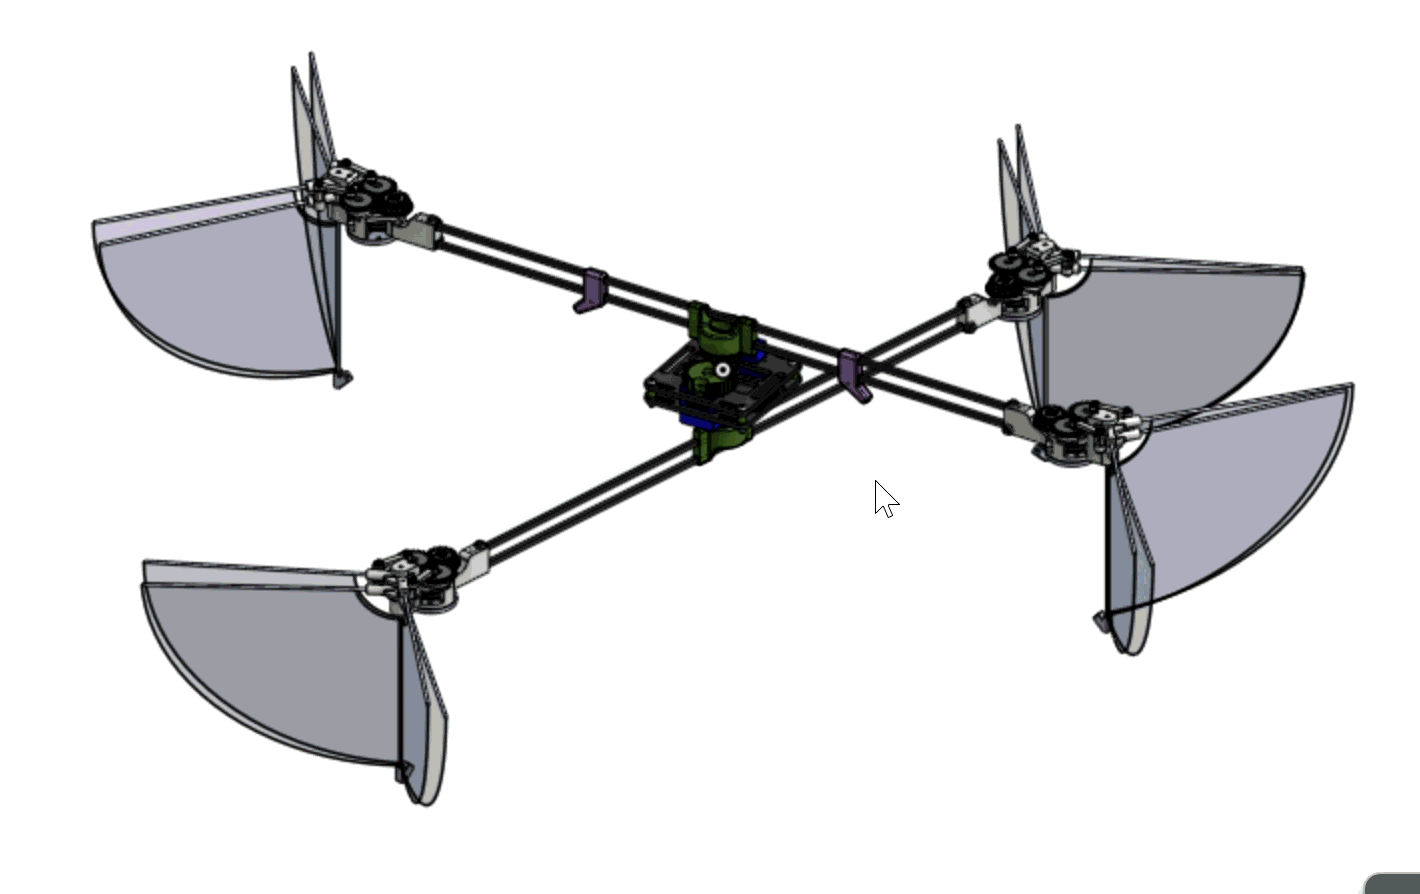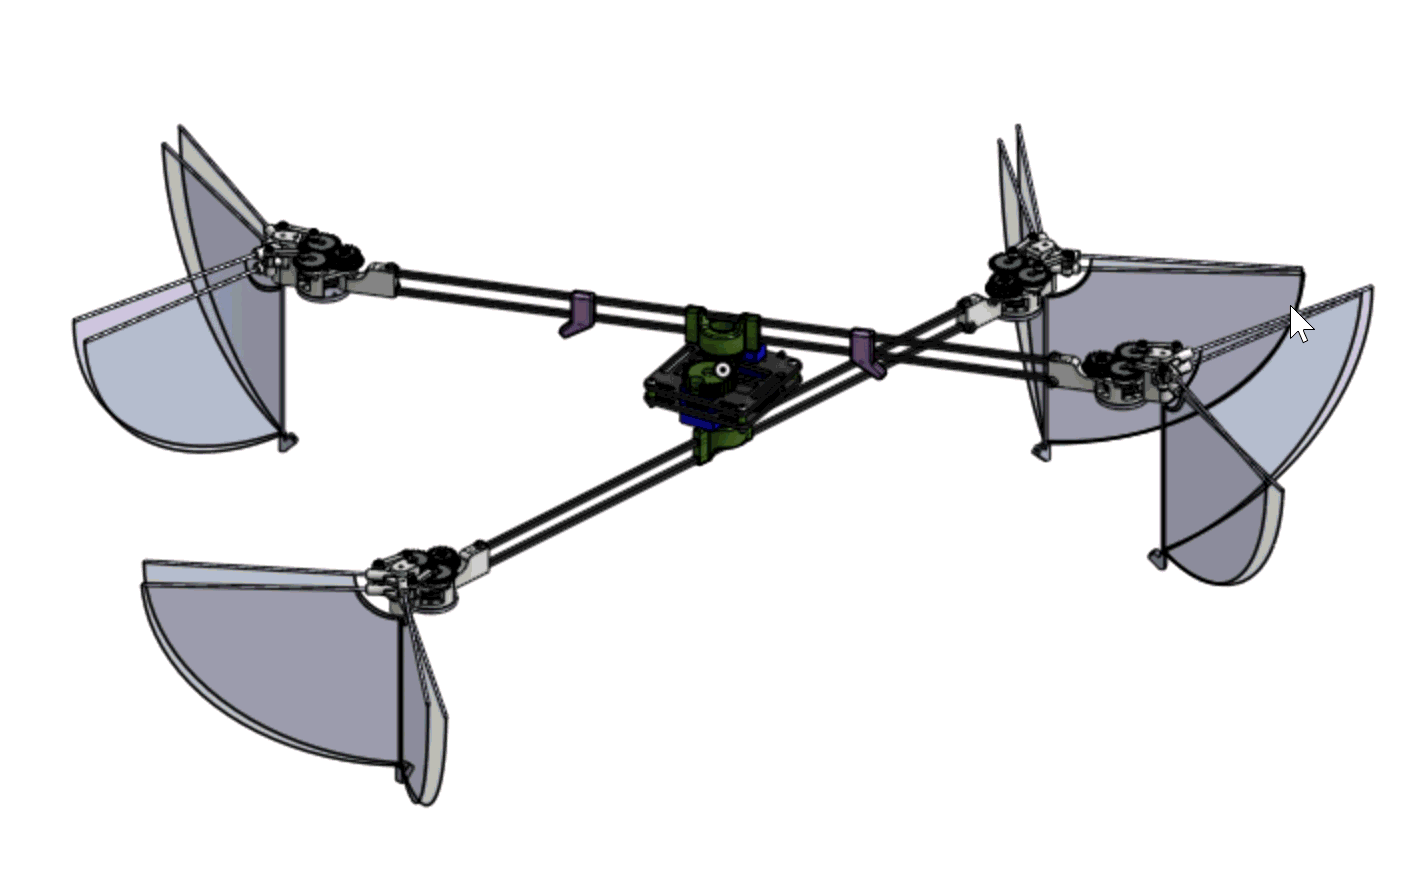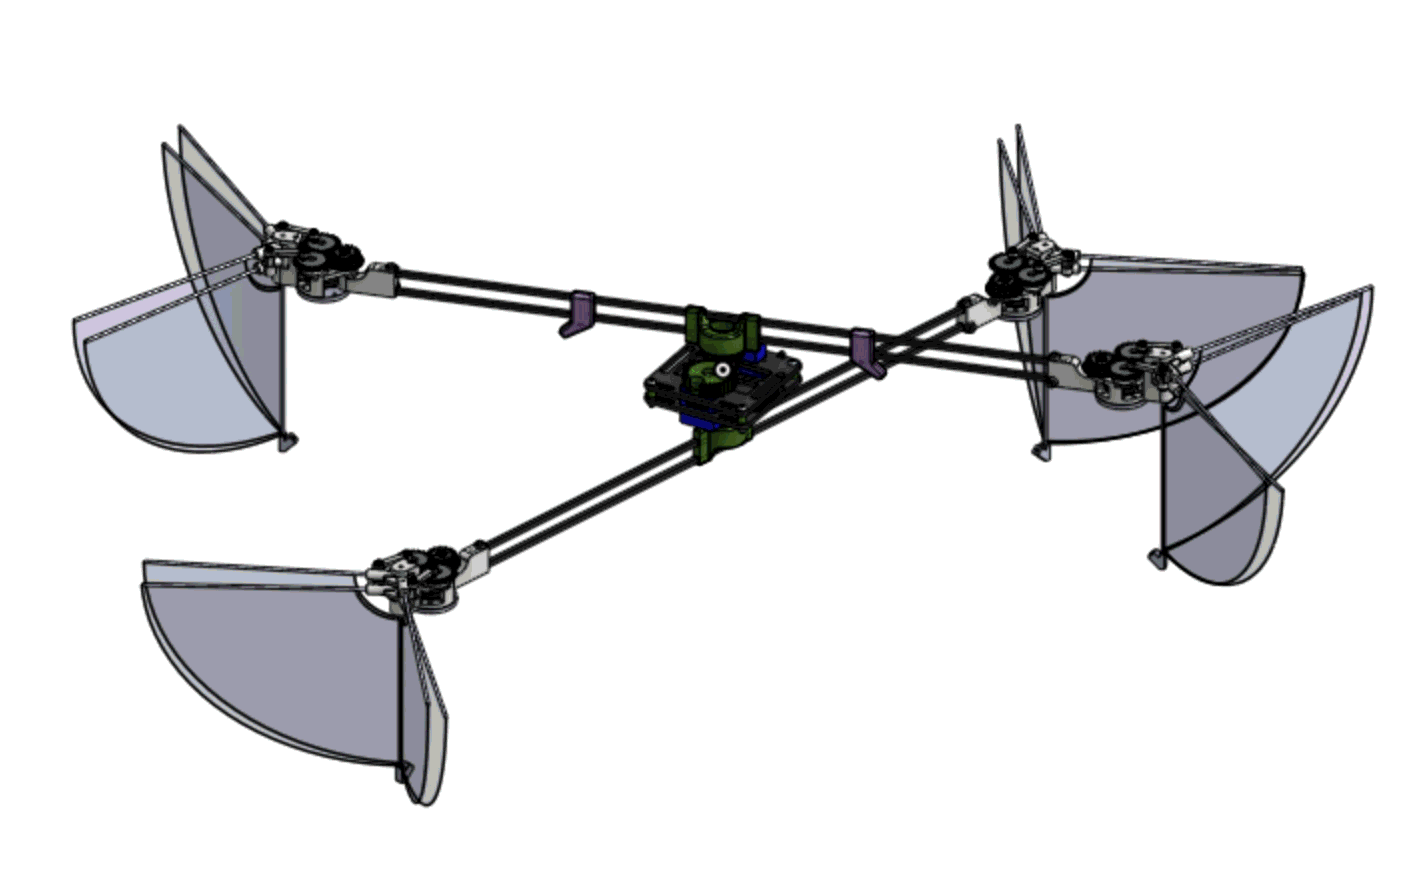
The X-Wing Quadflapper is a variable-geometry aerial vehicle designed to change shape mid-flight for different mission needs. By shifting into a tighter configuration, it can maneuver through smaller spaces and improve agility during complex movements. It can then return to a wider, more stable shape for controlled flight, making it a versatile platform that balances maneuverability and stability in a way traditional fixed-frame drones cannot.
2026-2027 Goals:
-
Reduce overall weight
-
Test flight maneuverability with frame changing shape
-
Test quadflapper with propellers and then wings
-
Create new landing gear
More About Novel 1 X-Wing
The X-Wing Quadflapper differs from traditional fixed-frame drones because it is designed to change geometry mid-flight. This allows it to navigate tighter spaces in a compressed configuration while still maintaining stable flight in a wider, square configuration. Its variable geometry also enables more aggressive maneuvers and improved agility compared to conventional fixed-frame designs.
Additionally, Novel 1 is a quadflapper that uses a flapping assembly similar to that of the Gamma subteam to generate lift. Research suggests that flapping-based flight can offer advantages in stability and efficiency when compared to traditional propeller-driven systems. When combined with Novel 1’s adaptive geometry, this creates a versatile aerial platform capable of operating in confined spaces while also expanding its range of possible mission tasks.
Ongoing research is focused on perfecting the design and further understanding the benefits of quadflapper flight as well as the performance advantages of Novel 1’s variable-geometry design.

